Protect the brake limits.
The first stress batch exceeded a specified brake-power ceiling in some cases. Pressure requests now include a worst-case torque-gain bound and a wheel-speed allowance for grip recovery.
P3.6 · Engineering development
A more detailed model brings wheel rotation, brake pressure and suspension into the airflow calculation. Explore its results and the first bench assembly.
Calculated performance. Nominal CAD. An unbuilt vehicle.
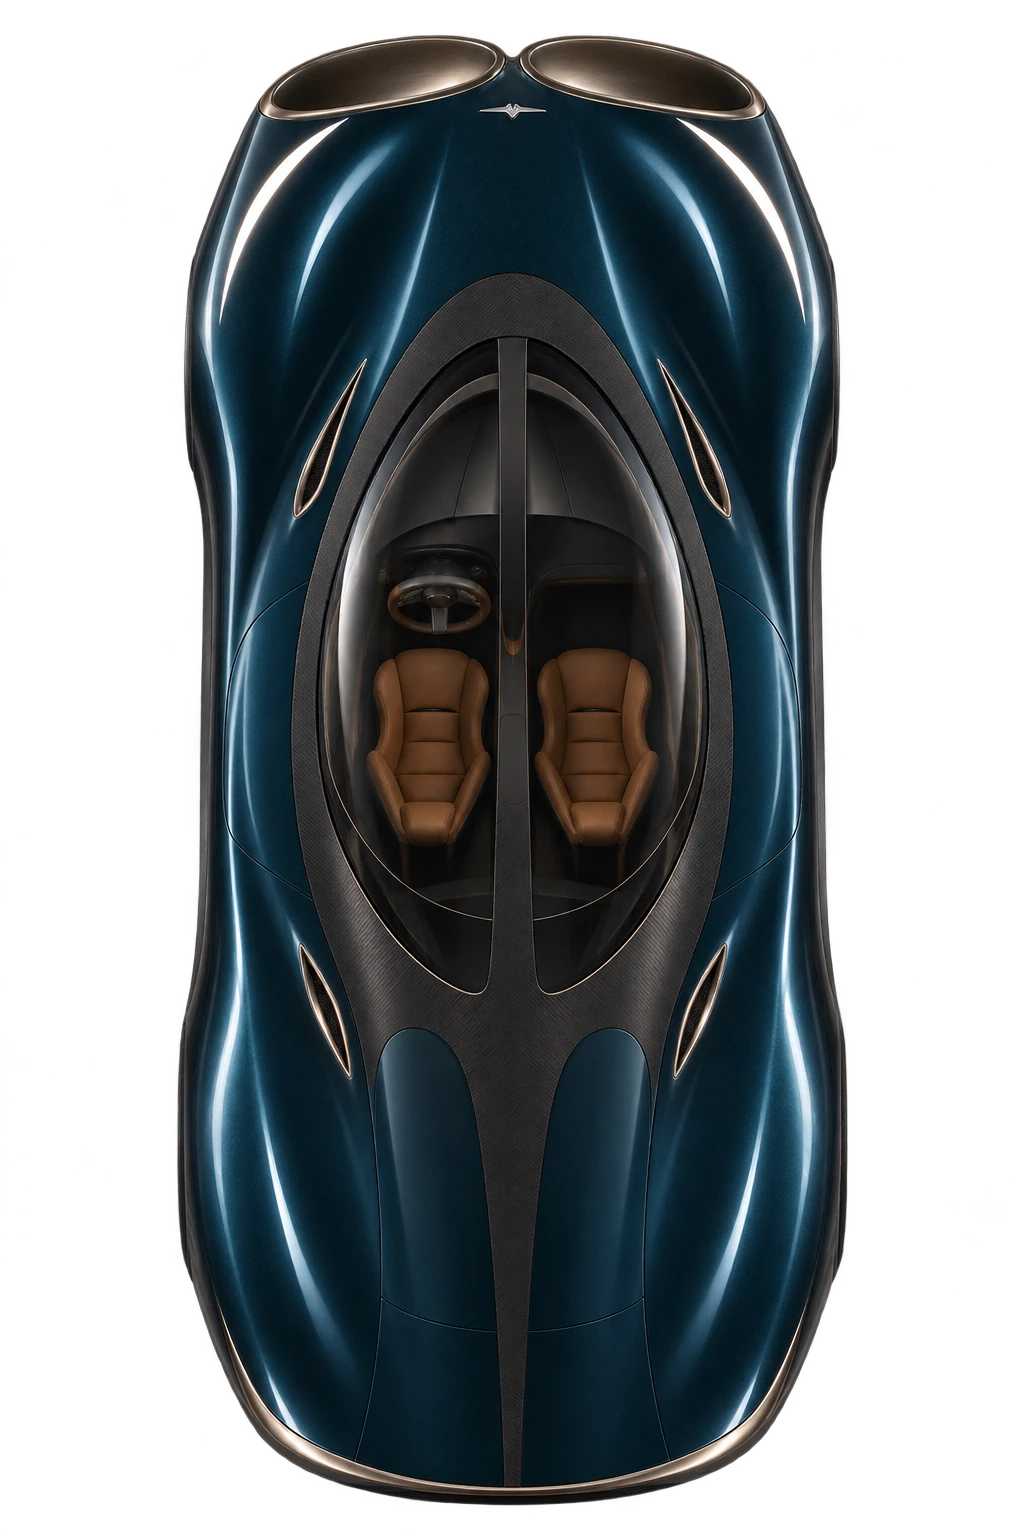
01 · Wheels, brakes, airflow and direction
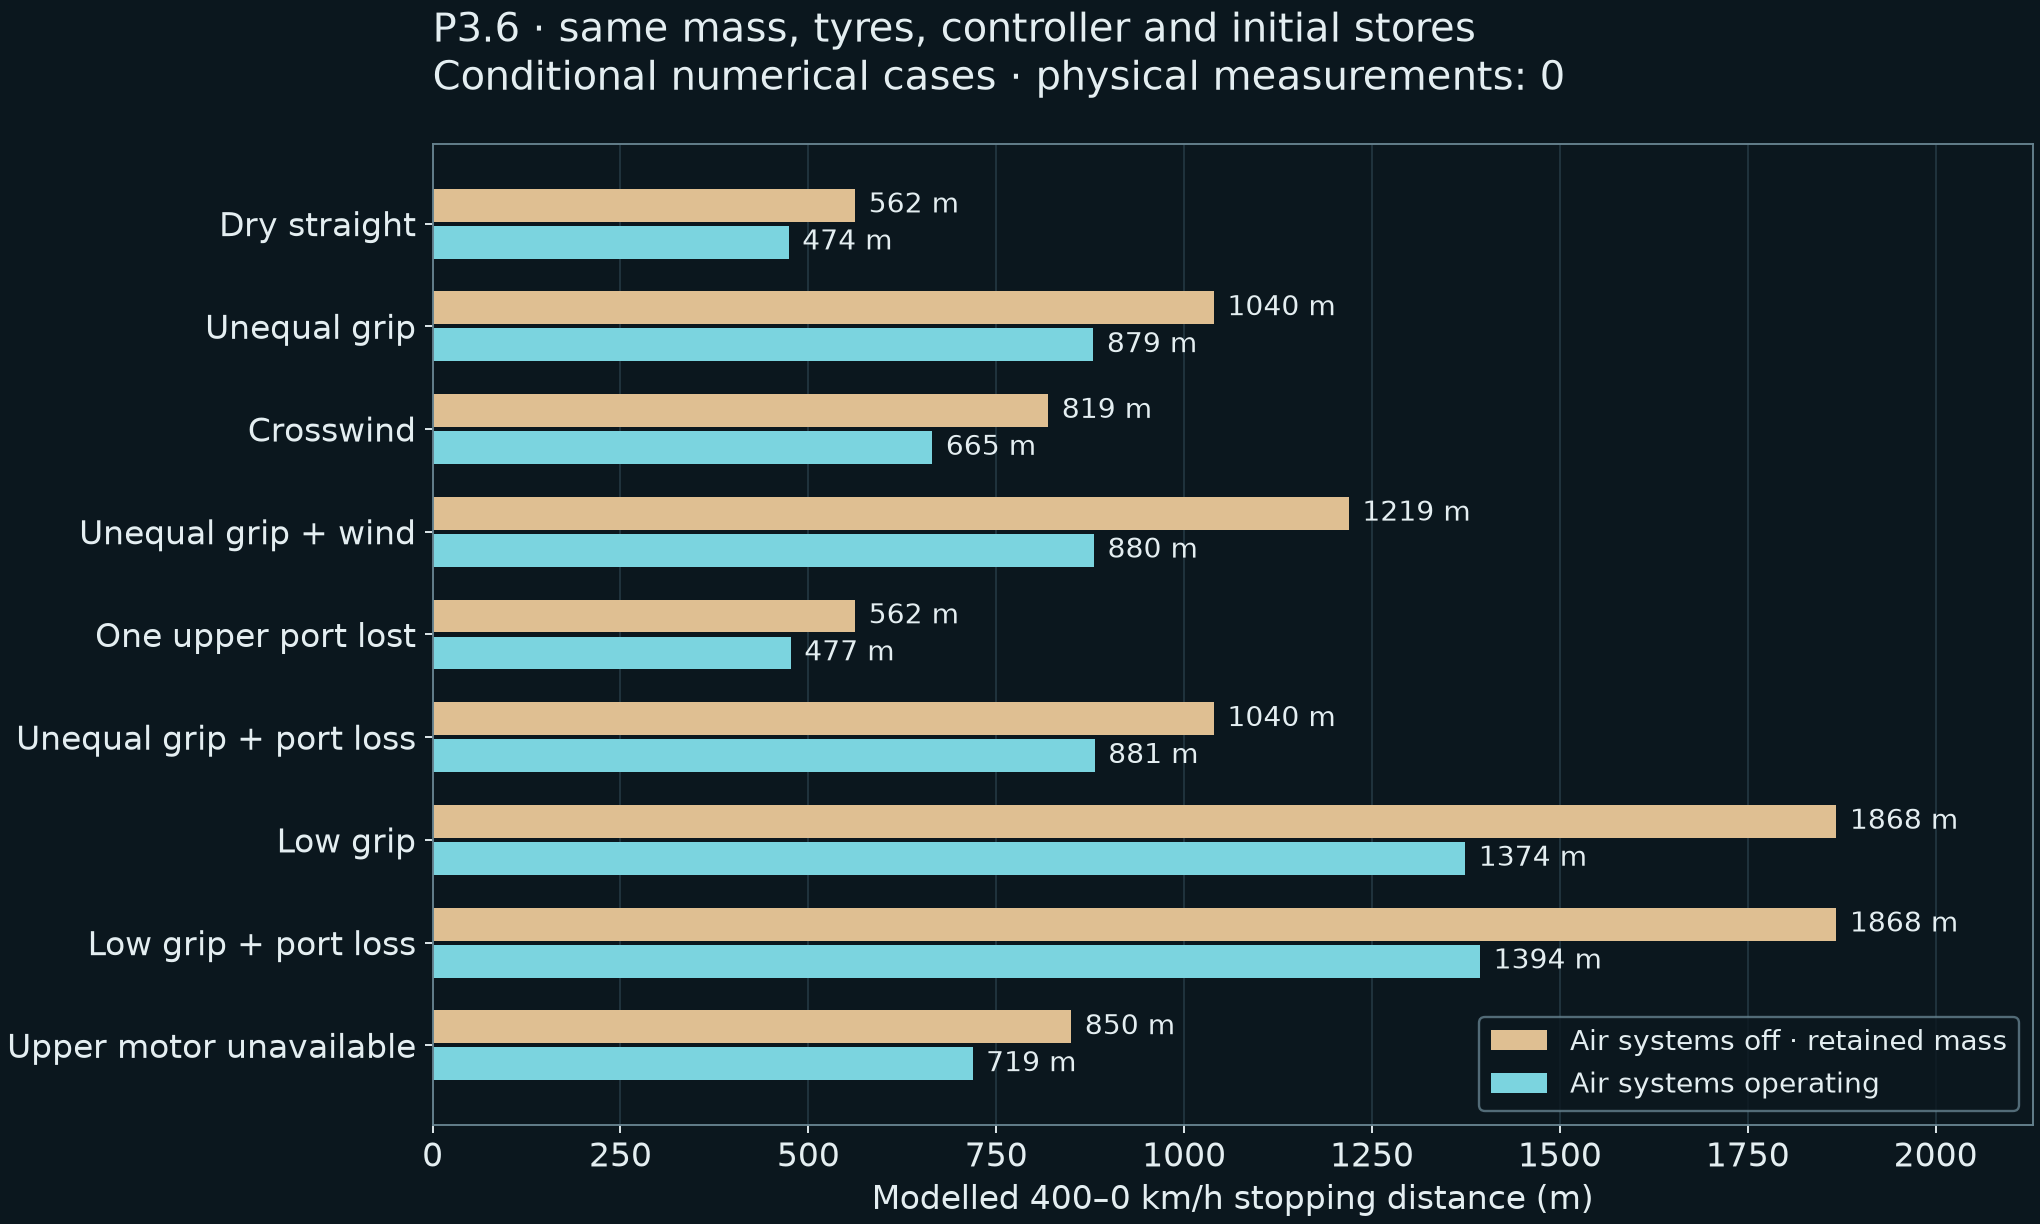
Replay the complete air system enabled and disabled in nine driving conditions. Inspect actual calculated pressure, slip, tyre load and rotor temperature while the car slows.
Same mass, tyres, controller and finite stores at 400 km/h.
Car styling and air paths are illustrations, not CFD. Plots and readouts use recorded model data. The direction test checks the rotated vehicle footprint in a 3.6 m corridor and peak heading below 3°. Grip multipliers describe synthetic conditions; they are not measured snow or ice coefficients.
02 · A more demanding comparison
Both cases carry the same {{MASS}} kg, use the same wheel and tyre model, and start braking with the same finite energy stores. Enabling the upper routes and powered underfloor system reduces the dry stop by {{GAIN}}% in this model.
P3.5 used ideal wheel-force control and quasistatic load transfer. P3.6 replaces those shortcuts with rotating wheels, a force/slip curve, pressure dynamics and heave, pitch and roll. Its distances are therefore revised. The two revisions are different models.
Bugatti publishes 491 m for its Chiron’s 400–0 km/h stop. The present CryoPulse projection is numerically shorter, but its small margin over that measured reference is not independently validated. The earlier baseline fit and assumed component targets do not establish production-car superiority.
Acceleration and unrestricted speed remain earlier, separate longitudinal studies. This revision does not upgrade those projections into a validated whole-vehicle benchmark.
Bugatti’s published data ↗| Condition | Air off | Air on | Air-on peak lateral position | Air-on peak heading |
|---|
03 · Fix, rerun, retain the evidence
The first stress batch exceeded a specified brake-power ceiling in some cases. Pressure requests now include a worst-case torque-gain bound and a wheel-speed allowance for grip recovery.
Other early runs exhausted the pulse budget required for actuation. The controller now protects a 100 kJ control reserve and budgets fan draw over a finite reserve horizon.
The revised brake command includes a damped allowance for measured wheel deceleration. A half-strength setting improved all three tuning conditions; stronger gains increased distance in the unequal-grip and wind case.
Wheel encoders, delayed vehicle-state feedback, pressure and an assumed brake-torque map drive the response. The controller receives no true road-grip value. Its grip estimate remains conservative after saturation; grip recovery is not actively probed.
The model checks contact loss, suspension travel, friction work, brake power, finite stores and the shared electrical node. Halving the timestep changes the selected distances by {{TIME_CHANGE}}% or less.
The separate pressure study varies upper-outlet backpressure and useful motor output while electrical draw stays unchanged. It retains a braking benefit in the tested combinations, but it is a boundary sensitivity, not a measured installed-flow map.
{{PRESSURE_SUMMARY}}
Read every pressure and motor-loss case ↗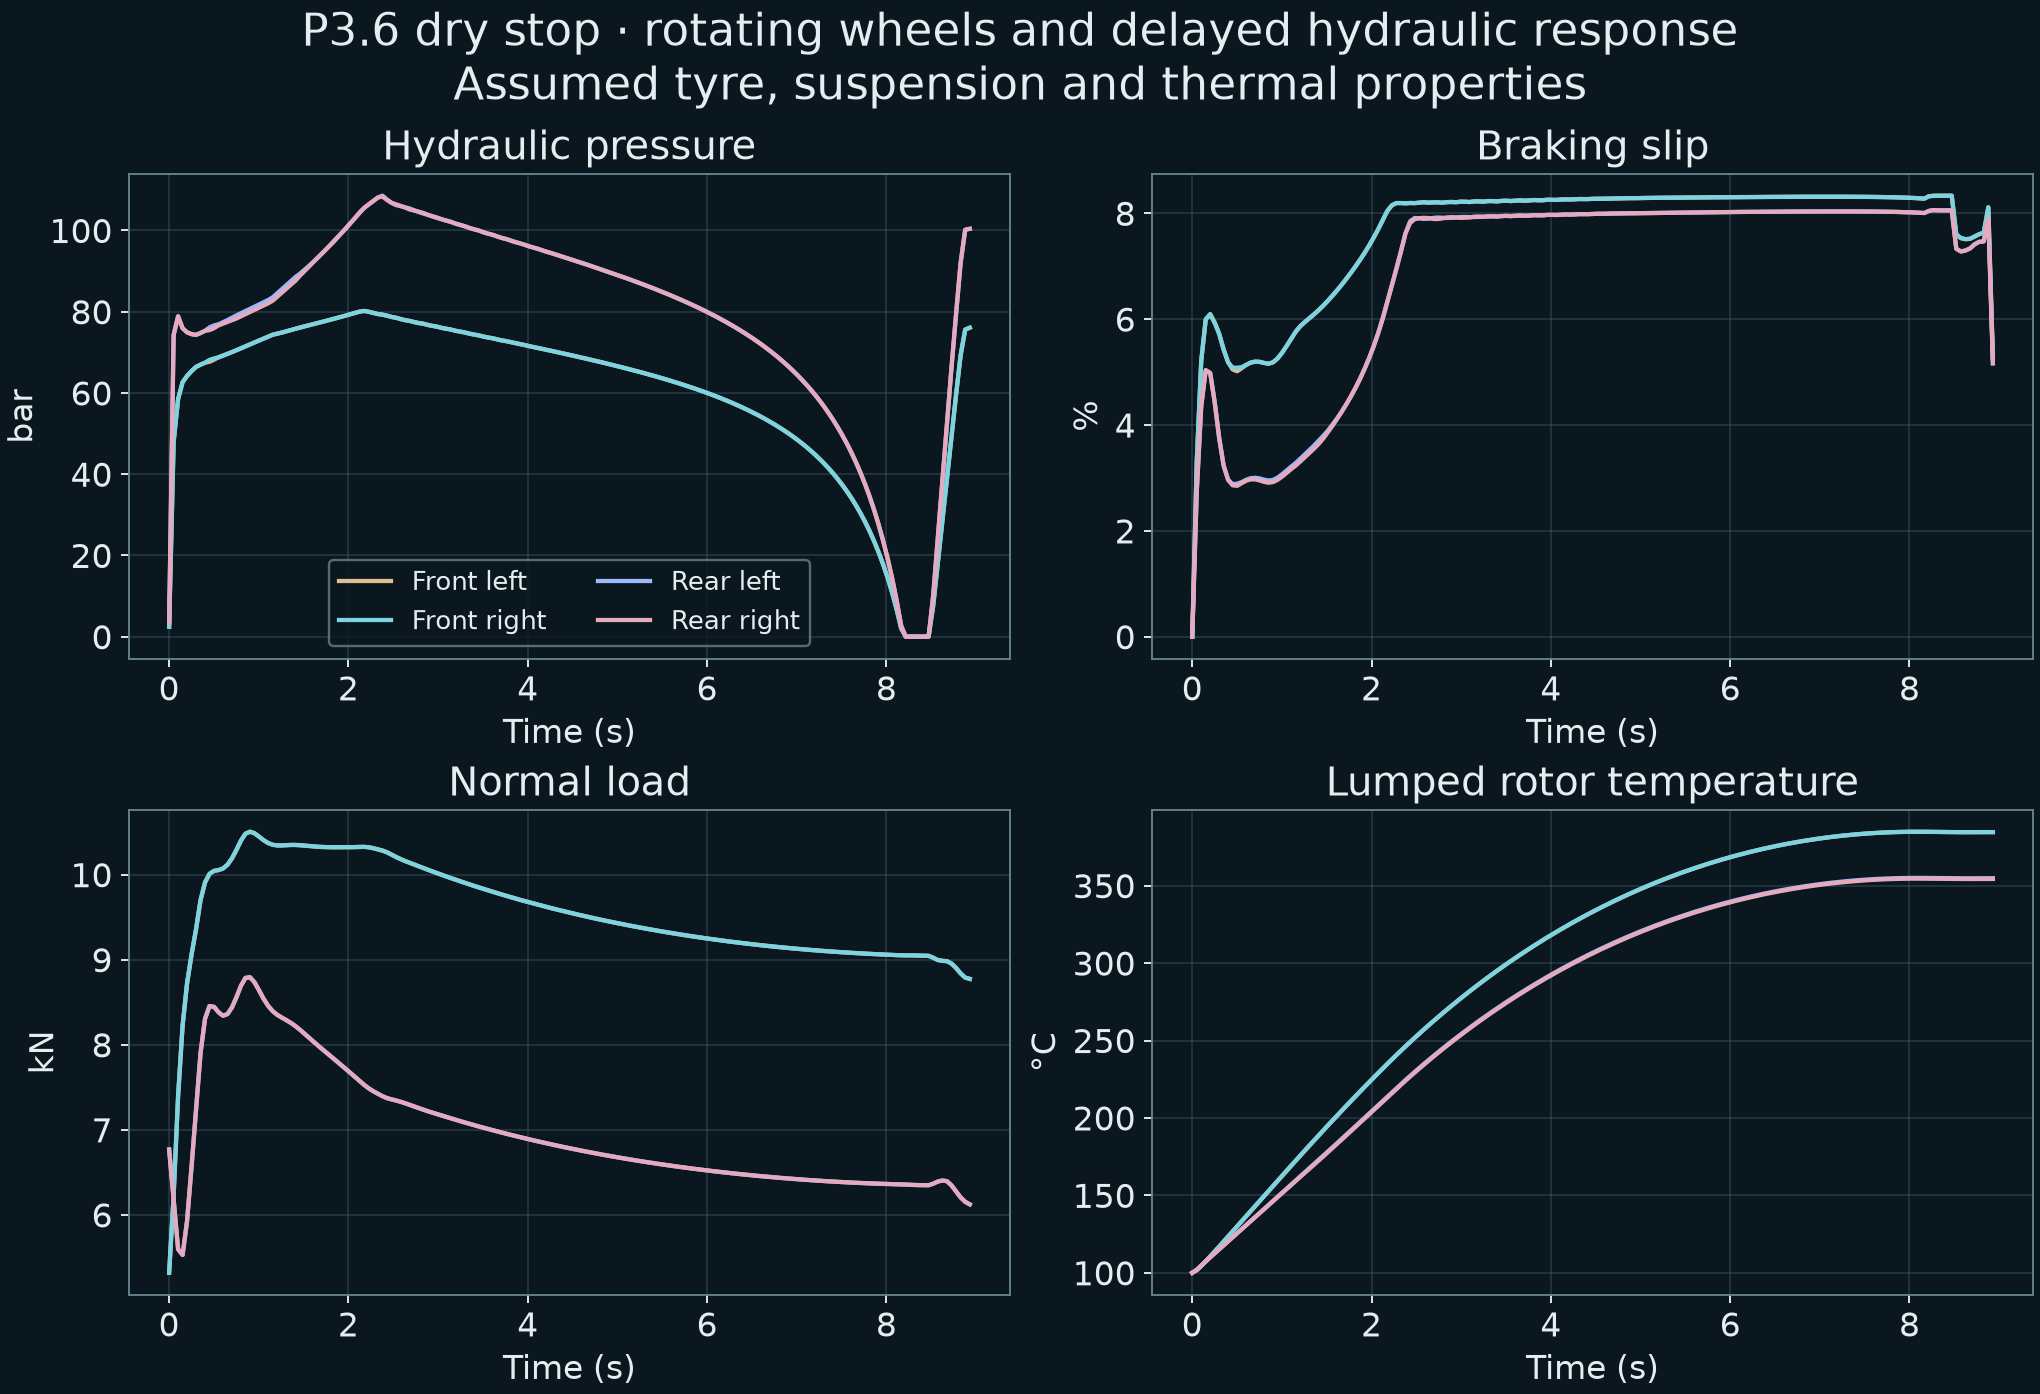
04 · The first physical build
Nominal assembled geometry
Machined housing. Split valve stubs. Soft seats. Dry bushes. Keyed hubs. Actuator supports. The servomotor shape comes from the manufacturer’s STEP file and mounting drawing.
The bare outlet bore increased to 30 mm to make room for the seat and the real obstruction from the gate and stubs. Its open clear area is {{AREA_PERCENT}}% of the earlier unobstructed reference area. That is a geometric area check; the flow coefficient still has to be measured.
All three sampled rigid poses clear the housing and bushes. The intended elastomer preload is excluded from that check. Leakage, friction, continuous motion, welds and pressure duty remain qualification work.

Housing & valves
Hard-anodised aluminium housing; stainless gate and stub assemblies; qualified dry bushes and soft-seat compound. Housing metal mass: {{HOUSING_MASS}} kg at the assumed density.
Actuation candidate
Metal gears, position feedback and supplier CAD. A 250 ms bench stroke is a test target. The quoted 0.93 Nm is stall torque; continuous duty and the car’s 150 ms target remain unqualified.
Manufacturer specifications ↗Measurement candidates
ATI Nano17 six-axis balance and a dry Sensirion differential-pressure sensor. The complete mounted rig must demonstrate its uncertainty; sensor resolution alone does not establish it.
Read the full test protocol ↗Put the two candidate blowers, collector, manifold and valves on one balance. An external feed hose can apply pressure forces that look like a duct benefit. Keeping the complete air unit inside the measurement boundary removes that ambiguity.
A parallel pair of 24 V Sanyo Denki blowers is a candidate for the dry-air rig. Each has a 410 Pa catalogue static maximum and a 1.04 m³/min free-flow maximum. They are different operating points. The installed curve must be measured.
Blower specifications ↗Signal-size planning · uniform jets
Predicted downward reaction from four 30 mm exits at 130°. The assumed flow is an input, not a blower prediction.
Mounted-system expanded force-uncertainty target: 0.02 N. Velocity profiles, outlet pressures and real calibration determine the measured result.
05 · The cold branch, with its hardware costs
Cooling can create a pressure difference. A prepared cold store can also absorb heat and support a finite recovery cycle. The new screen includes exchanger packaging, warm startup, pressure losses, auxiliary power and added mass.
Initial inventory target.
About {{STARTUP_N2}} kg is allocated to warm-hardware cooldown.
Finite thermodynamic duty.
Two counterflow exchanger targets and real-fluid states.
Calculated DC recovery.
Startup pump, control, generator, blower and coolant-pump allowances included.
The driving results receive no cold-energy boost.
Hardware mass is carried in a separate control.
The separate wet-hardware mass target adds {{COLD_MASS}} kg. Recomputing the earlier acceleration initializer and then the wheel-dynamic stop gives {{COLD_STOP}} m with air systems on, versus {{COLD_OFF}} m off. This sensitivity carries the mass before awarding any unmeasured cold output.
The selected pre-cool bypasses the warm air and coolant streams for a target 120 seconds. It includes the declared wetted masses of both exchangers, piping and the expander, plus startup pump and control input. Heat-transfer coefficients, rib support, pressure drops, startup temperature and equipment masses are targets. This is a packaging and thermodynamic screen, not a fabrication-qualified cryogenic system.
Preparing the full {{INITIAL_N2}} kg nitrogen charge has a calculated reversible-work lower bound of {{RESET_MJ}} MJ, already much larger than the selected net electrical recovery. Unspent liquid and residual cold-gas availability are credited separately in the resource ledger. The charge-preparation number is not the amount spent.
The useful questions are heat management, finite power recovery and integration. There is no self-charging or net-energy claim.
Explore the finite cold-pressure demonstration ↗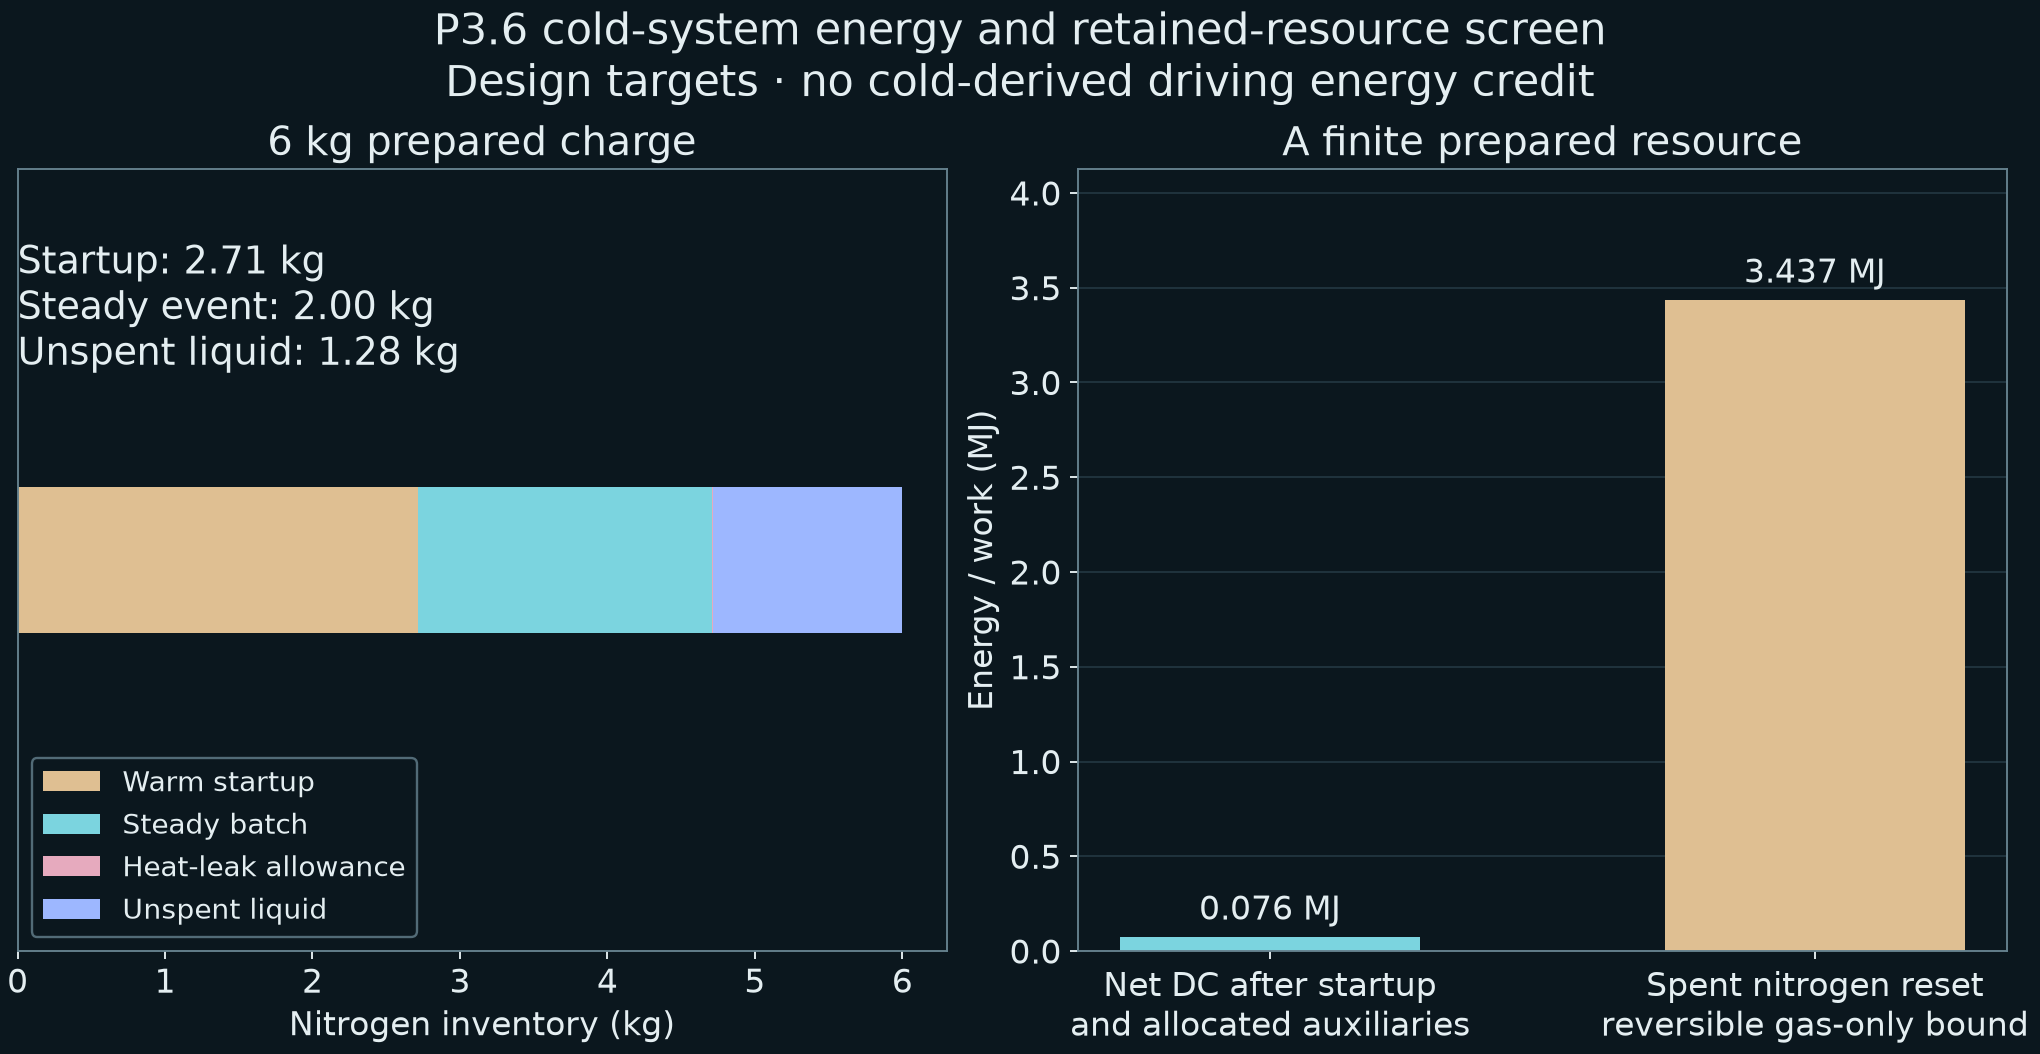
06 · Installed airflow
The engineering CFD proxy now has moving ground, rotating wheels, wheel arches and an approximate loaded contact footprint. The body’s external shape and internal paths remain part of the same airflow problem.
{{CFD_SUMMARY}}
No low-speed CFD coefficient is transferred into the 400 km/h performance model. The full installed fan, upper-outlet and thermal-core interactions are still to be qualified.
The open-body mesh passes the complete topology and geometry checks, including cell connectivity and convexity. Interior-node repairs preserve its CAD surface vertices and triangles.
A mesh check is one stage. Converged forces, mass conservation, wake sampling, wall treatment, refinement and time resolution are separate checks.
Read the current flow-calculation record ↗07 · The engineering record
Wheel, contact, suspension and full-event mechanical-work identities close within their numerical tolerances. The electrical stores remain finite, pressure and power ceilings are checked, and reflection and timestep comparisons are retained.
The tyre model is empirical. Rotor properties are lumped targets. Unsprung vertical motion, coupled ride height and skirt following, a measured tyre-temperature map, structural qualification and installed component maps are absent. Acceleration still uses a separate earlier initializer.
The original P3.6 stress batch passed 41 of 48 sampled plant combinations. Four exceeded a design brake-power ceiling and three exhausted the required pulse actuation budget. Those observations led to the torque-gain bound and protected control reserve. Repeated cases became development checks.
The later inertia-feedback study retained every gain tried, including settings that increased distance in unequal grip and wind. The selected reduced gain is checked on the full regression set and fresh combined cases. None of the retained failures is silently reclassified as success.
Read the retained design history ↗Carbon structure, premium brake materials, high-speed tyre development, thermal management and accessible doors remain in the full programme. Supplier technology can inform a target; a brand name does not establish the friction, heat capacity, stiffness or speed rating of this proposed vehicle.
The bench’s 6061-T6 housing and 316L valve components are specific material targets for a low-pressure experiment. Their use does not qualify an installed automotive or cryogenic part.
Brembo: carbon ceramic brake technology · Michelin: high-speed tyre development · The complete CryoPulse vision.
MathWorks: combined-slip wheel equations · NASA: momentum and pressure thrust · NASA: mesh-convergence assessment · CoolProp: nitrogen properties · P3.3 shared-resource model · P3.4 outlet and axle model · P3.5 visual model.
These sources support established mechanisms and equations. They do not validate CryoPulse or imply supplier endorsement.